Motion Control & EtherCAT Integration
Two ports, one bus
Motion control and EtherCAT integration start at the machine: the servo axes, the field devices and the communication between them. SPEKTYR’s wireless EtherCAT module connects two M12 ports straight to a decentralized servo and carries full bus performance over the air, with hard real-time determinism.
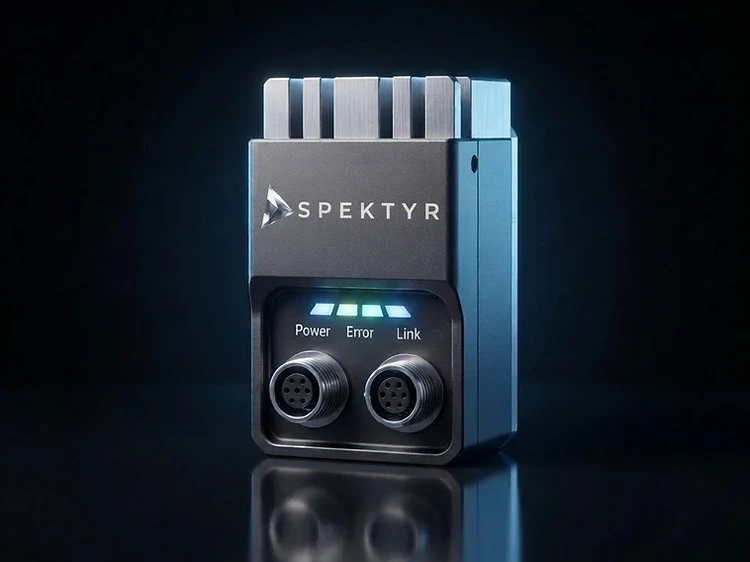
Wireless EtherCAT: full bus performance without the cable
Wireless EtherCAT dissolves the cable. Two M12 ports link straight to a decentralized servo and carry full bus performance over the air — with the hard real-time determinism EtherCAT is known for.
What the wireless EtherCAT module does
Bus performance, wire-free
Full EtherCAT cycle times delivered wirelessly, so a decentralized servo behaves exactly like a cabled one.
Two M12 ports
Rugged industrial connectors in, rugged industrial connectors out — no fragile consumer hardware on the cell.
Hard real-time over the air
Deterministic 5.2 ms cycles with guaranteed latency, not best-effort networking.
Decentralized by design
Mount the servo where the motion is, not where the cable reaches. Layout freedom without performance compromise.
Let’s build your control system.
Tell us what you’re automating and where the blocker is. From IPC, HMI, and wireless EtherCAT to Spektyr PLC, our CNC kernel, and hands-on programming services — we’ll set up a meeting, define the scope, and agree on the goals. You only pay when each one is delivered.